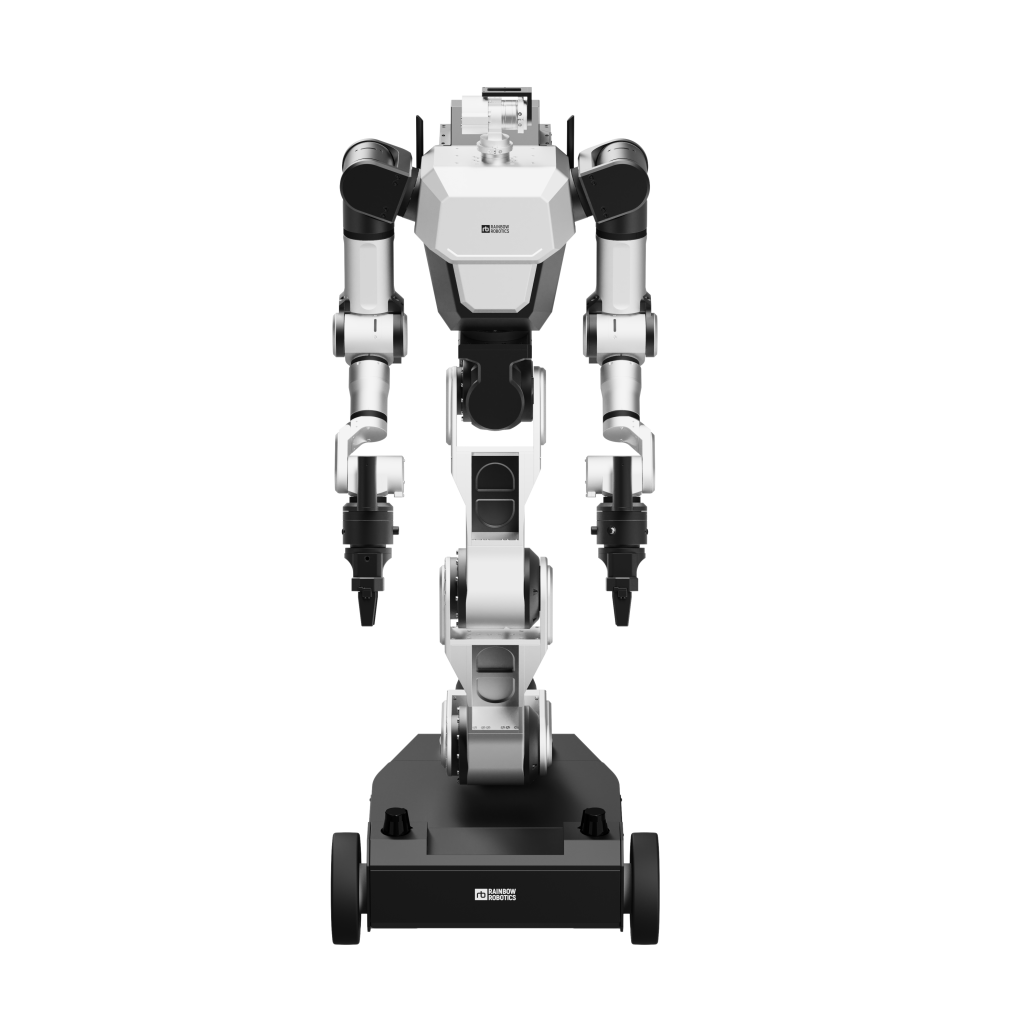
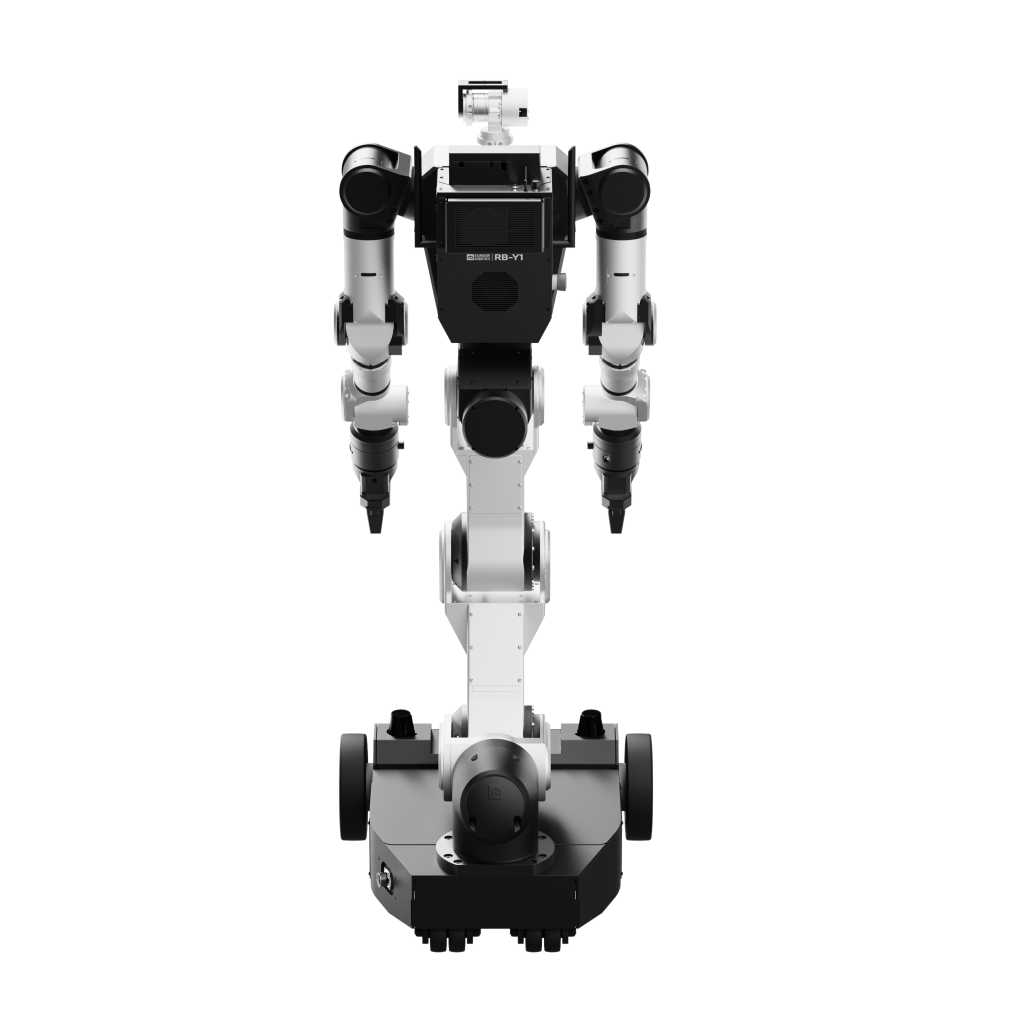
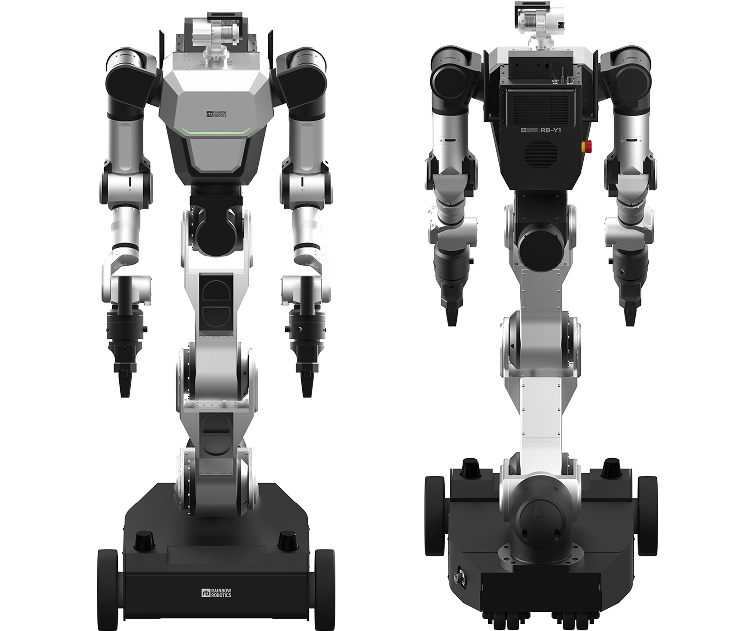
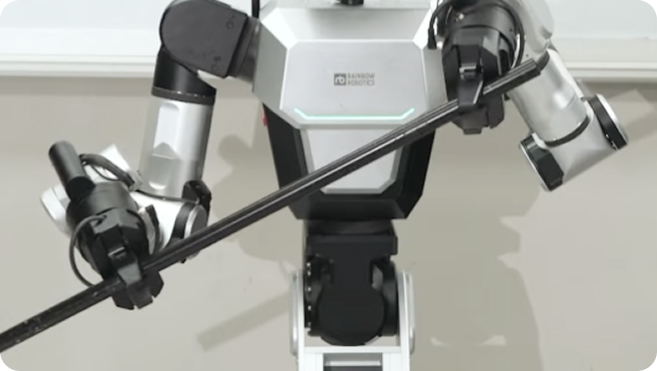
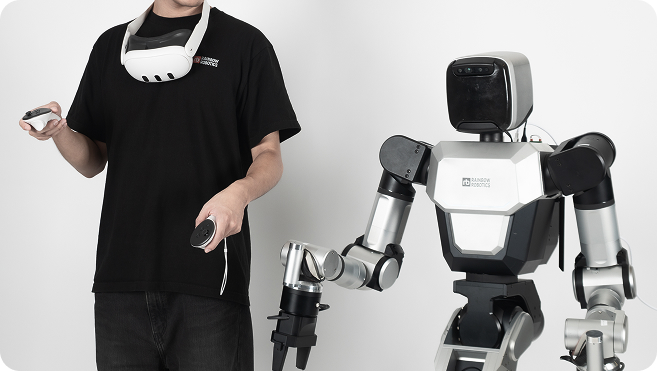
RB-Y1 is a mobile dual-arm robot platform for research, designed to integrate mobility, manipulation and perception experiments. The official specification presents A and M configurations; configuration-dependent values are kept explicit.
Specifications
| Overall height | 1,400 mm |
|---|---|
| Total weight | 131 kg (A configuration) / 170 kg (M configuration) |
| Degrees of freedom | 20 DOF (A) / 26 DOF (M) |
| Arm payload | 3 kg per arm |
| Arm reach | 600 mm to wrist + hand |
| Driving speed | 1.5 m/s |
| Battery capacity | 1,250 Wh (A) / 2,500 Wh (M) |
| Dimensions | 600 × 690 × 1,400 mm (W × D × H) |
| Operating temperature | 40 °C (official stated value) |
| Communication and software | ROS 2, RB-Y1 SDK, RS-485 |
| Arm repeatability | ±0.05 mm (based on collaborative robots) |
| Power | 48 VDC |
Technical extensions
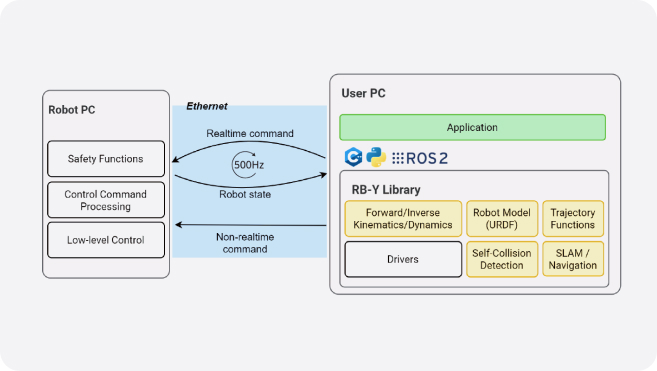
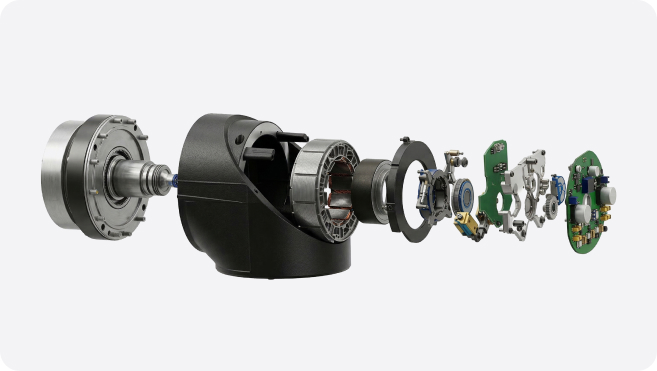
Official page also reports arm repeatability ±0.05 mm (based on collaborative robots), 48 VDC power specification, low-level position-reference/tracking/temperature/overcurrent/communication monitoring and high-level current limiting. Configurations A/M differ in wheel count and battery; dual-PC architecture separates real-time robot control from user applications. Optional neck joint, gripper and mobility/interface expansions are described on the source page.